
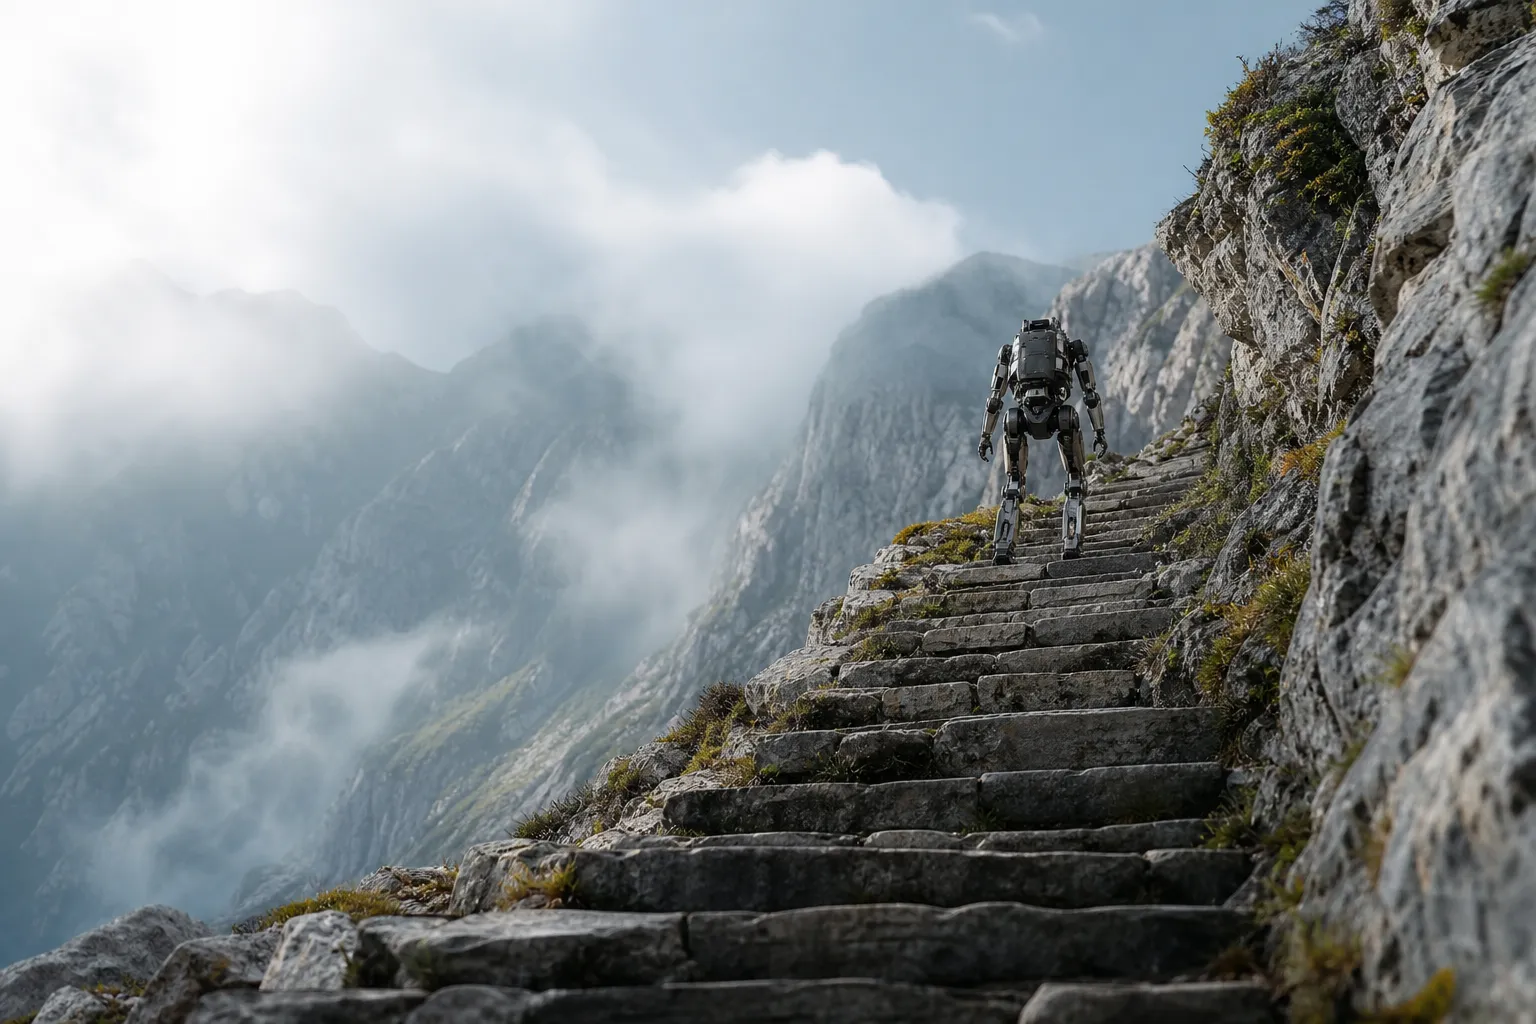
On 2 November, China will launch the first CMG World Mount Tai Robot Climbing Competition. Humanoid and quadruped robots will have to tackle 3,100 steps and 600 metres of elevation gain, using perception and balance systems adapted to the terrain.
In Tai’an, in China’s Shandong province, robots from several categories are preparing for a competition held on the historic paths of Mount Tai. Presented by CCTV News on 1 November, the event is meant to expose the machines to the difficulties of a real mountain environment rather than the controlled conditions of a laboratory.
Mount Tai robot climb: a 3,100-step mountain route
According to the information presented by CCTV News, participants will follow a route from Hongmen to Zhongtianmen. The course includes 3,100 steps and 600 metres of elevation gain, with stairs of varying height and width as well as cobbled sections.
For Su Qingwei, the competition’s chief referee, adapting to these irregularities is the main technical challenge. The robots must recognise the characteristics of the path and adjust their movement to the obstacles they encounter.
The competition also serves as a testing ground for robotic technologies designed for mountainous terrain. The organisers say the aim is to support their development for practical applications.
How humanoid robots climb stairs: sensors and balance control
Before the climb, the bipedal and quadruped robots survey the entire path to map the terrain.
Quadruped robots have a more stable base of support and a flexible gait. According to explanations broadcast by CCTV News, they can move quickly once they have identified the general direction to follow.
For humanoids, getting around involves different constraints. Their higher centre of gravity requires precise posture control, and each step demands an adjustment of the movement.
Some humanoid robots therefore have visual sensors mounted on the chest rather than higher up. This placement lowers their field of perception so they can better see the steps and the area just in front of their feet.
Foot placement control is another key component. When the foot touches the ground, the robot uses the forces acting on its joints and data on its posture to adjust the length of the next step and keep its balance. These corrections happen continuously, in real time.
Competition rules: referees move to fixed positions after qualifying rounds
The earlier qualifying rounds also led to a change in the rules. The robots sometimes moved too fast for the referees to follow them on foot over the whole distance.
The organising committee therefore replaced continuous tracking of participants with a fixed-point refereeing system.
Su Qingwei attributes this change to the difference in endurance between electric machines and the people monitoring them. After a battery swap, a robot can keep moving at a steady pace, while the referees remain bound by their physical limits.