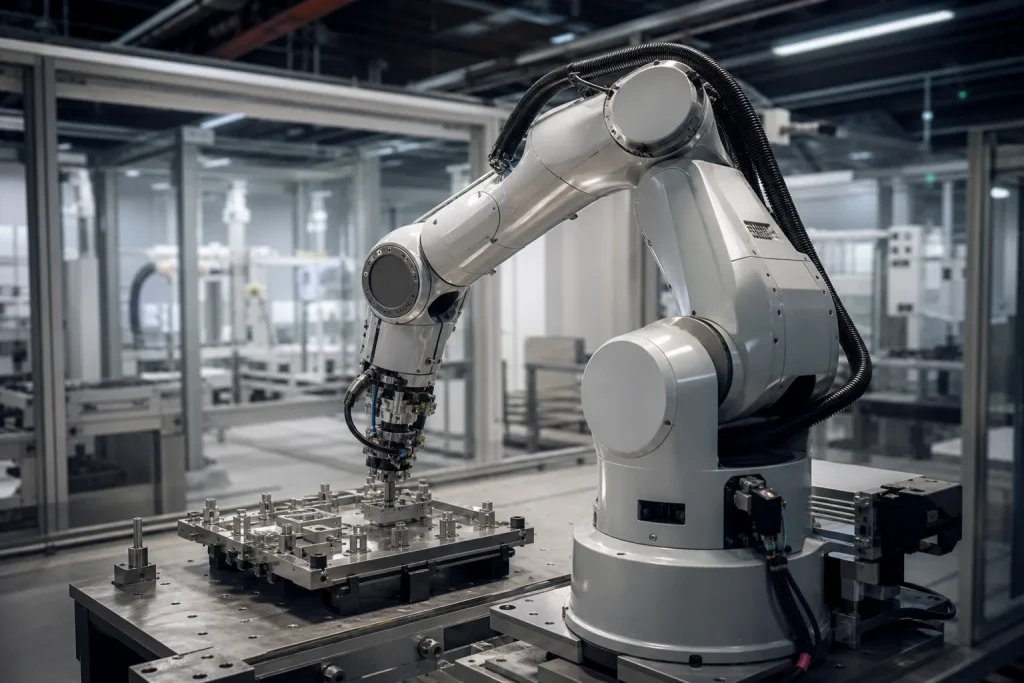
Voraus Robotik presents a method for making an installation of five industrial robots more flexible without replacing its control system. The approach combines artificial intelligence, a digital twin and software testing before deployment.
The project was presented by Christoph Brenken, head of technical business development at Voraus Robotik GmbH. It involved a robotic installation that had evolved over the years and now had to adapt to production with a larger number of variants. The mechanical equipment could carry out the required operations, but the programmable logic controller (PLC) and robot programs made changes difficult. The company therefore began a step-by-step modernisation of the control system, with the aim of keeping production running.
How a shared data layer reuses existing PLC and robot programs
The first stage of the project was to analyse the installation without modifying its control system. Voraus Robotik worked from the PLC and robot programs, computer-aided design (CAD) data, technical manuals and electrical diagrams.
Data was also collected directly from the fieldbuses so that the technical documents could be checked against how the equipment actually behaves.
An artificial intelligence pipeline turns this information into a hardware-independent representation. It combines components that can read the original formats, large language models (LLMs) and a predefined output structure.
Machine, control and process data are gathered in a shared layer that operators and AI tools can access. Voraus Robotik relies in particular on the open standards OPC UA and MQTT to connect this information.
Digital twin replicates robot motion and control logic
From this representation, Voraus Robotik built a digital twin of the robotic installation. It reproduces the kinematics of the equipment, the operating sequences and the control logic.
The simulation makes it possible to visualise the interactions between the different cells. Structured execution traces show, for example, when a robot is waiting for a part, for an operating release or for another cell to act.
The team also defined performance indicators to track improvements. The metrics include cycle time and production throughput for each variant manufactured.
The digital twin thus provides a shared environment for analysing how the installation runs, preparing changes, supporting commissioning and making maintenance easier.
How AI assigns orders based on the status of each cell
Order management is one of the main changes introduced in the project. Orders used to be distributed according to fixed patterns. They are now assigned dynamically to cells based on the current state of the installation, according to Voraus Robotik.
Analysis tools and AI agents suggest optimisations based on the collected data and the digital model.
The system relies on information flowing in both directions: the machines send their operating data, while control decisions are sent back to the equipment.
This setup is intended to adapt production sequences to the different variants without completely rebuilding the existing control architecture.
Testing software changes in the digital twin before deployment
Voraus Robotik also applies the principles of Industrial DevOps, a method that brings software development practices to industrial automation.
Every change, whether it comes from a developer or an AI agent, goes through a series of automated tests in the digital twin before it is deployed on the real installation.
Only software versions that have passed all the tests can be deployed. The process covers planning, programming, testing, validation, deployment, operation and monitoring.
This procedure makes it possible to check changes in a simulated environment before applying them to the industrial robots. It is the validation mechanism Voraus Robotik uses to support the step-by-step modernisation of the installation.